Key News Facts
Following the launch of its RX business promotion office, Samsung Electronics conducted a demonstration in which a humanoid robot operated a camera directly (to take a photo) at its first management presentation. The robot hand uses a tendon-driven design developed by the Handrang team under the future-robotics promotion group.
Hand Lab is a dedicated robot-hand organization newly established under Samsung Electronics’ Future Robotics Office, aimed at advancing physical AI and developing practical robot hands (source: Electronic Times, Mar 10, 2026). As part of strengthening the team, Samsung reportedly recruited outside experts including Prof. Kim Eui-kyum of Ajou University (same source). The camera-grip demonstration took place at the Woomyeon-dong R&D Campus in Seoul, with DX Division head Roh Tae-moon personally attending (source: Money Today, Aug 10, 2026).
Mechanism-Perspective Impact Analysis
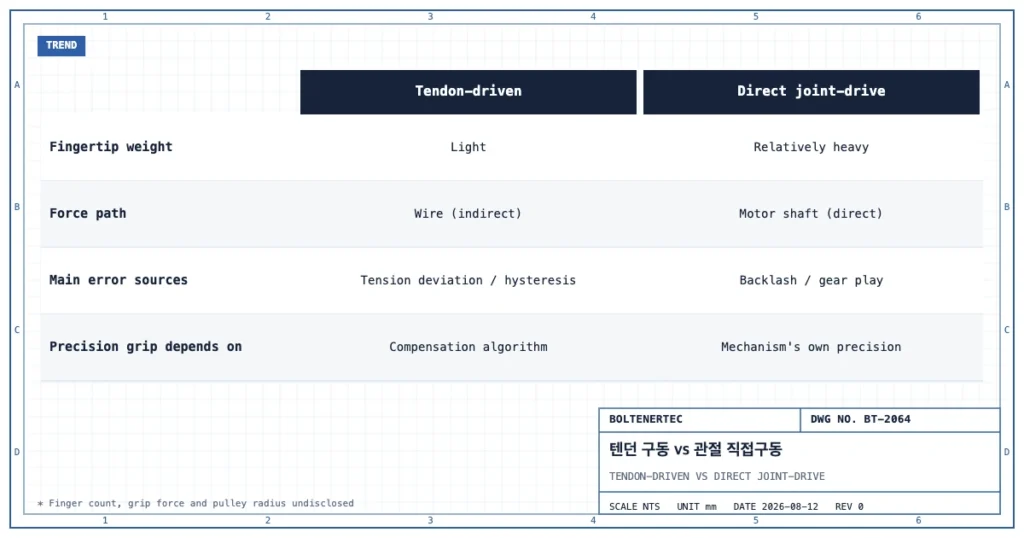
The tendon method does not place motors directly at the finger joints but instead drives them remotely through wires. While the fingertip itself stays light, wire-tension deviation and backlash (hysteresis) govern the repeatability of grip precision. For tasks requiring sub-few-mm micro-stroke manipulation, such as operating a camera shutter, hysteresis compensation is the core challenge.
According to Electronic Times, the tendon method pulls tendons from the forearm to move the fingers, similar to a human hand, and is structurally more complex and harder to assemble than a direct-motor-drive approach (source: Electronic Times). Samsung is reportedly also developing tactile sensing solutions to compensate for this, with an eye toward manufacturing-floor applications (same source).
Unconfirmed: Samsung has not officially disclosed the tendon system’s actual finger count, grip force (N), or pulley radius (mm), so these cannot be estimated at this time. At CES 2026, several Korean companies unveiled five-finger-driven robot hands (source: Nate News, Jan 6, 2026), but whether Hand Lab’s finger degrees of freedom match that level remains undisclosed.
Beyond Samsung, robotics firm 1X — backed by OpenAI and Samsung Electronics — has also unveiled a tactile-sensing robot hand (source: Nate News, Jul 10, 2026), signaling that competition in humanoid hand technology is intensifying. However, each company discloses its actuation method (tendon-driven vs. direct-drive) and detailed specs differently, making simple comparison difficult (unconfirmed).
Spec Comparison Table
| Category | Tendon-driven | Direct joint-drive |
|---|---|---|
| Fingertip weight | Light | Relatively heavy |
| Force-transmission path | Wire (indirect) | Motor shaft (direct) |
| Main error sources | Tension deviation / hysteresis | Backlash / gear play |
| Precision-grip difficulty | Depends on compensation algorithm | Depends on the mechanism’s own precision |
| Unconfirmed specs | Finger count, grip force (N), pulley radius (mm), etc. not disclosed | |
Shop-notes
An alternative to the assembly-intensive tendon method is a direct-drive approach with small motors placed at the finger joints, but this is judged not to have been adopted because it increases fingertip inertia, which is disadvantageous for high-speed grasping and collision safety (a general robotics trade-off; Samsung’s actual reasons are undisclosed). The same trade-off applies to gripper design for battery R2R equipment, and adopting a wire-driven approach requires a periodic maintenance procedure to recalibrate the friction coefficient as pulleys wear (on-site verification required).
Design Reflection Checklist
- Periodically re-verify the deviation between capstan-equation-based tension predictions and measured values when adopting wire-driven grippers
- Set a recalibration interval for the hysteresis compensation algorithm as pulley wear changes the friction coefficient
- Consider dual-sourcing actuation methods by use case: direct-drive for high-speed grasping, tendon-driven for lightweight precision grasping
One-line summary: The very mechanism that lightens the hand always shifts the burden onto the control side.